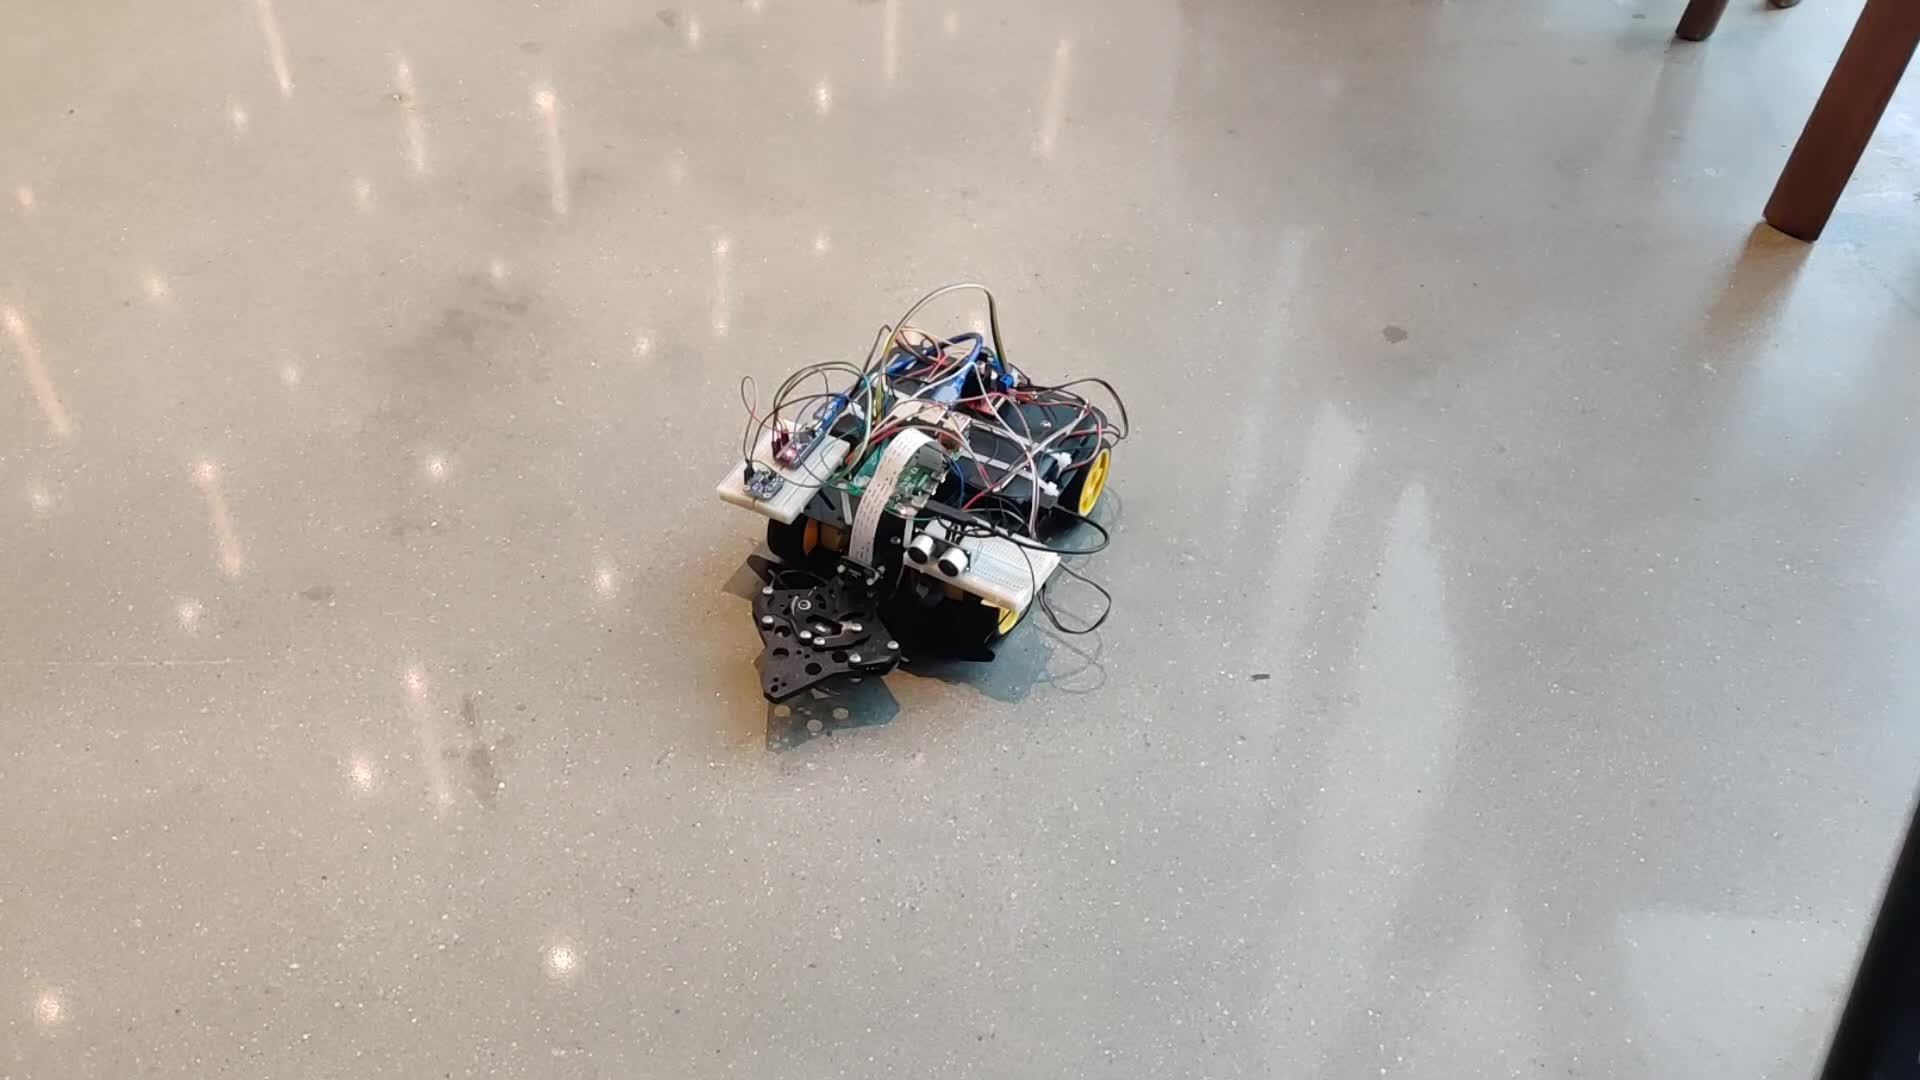
Fully autonomous mars construction rover
Building a fully autonomous rover to pick up colored blocks in specified order and drop them at storage location.
What's a the point of being a Sci-Fi enthusiast and a Robotics engineer if your robots aren't Autonomous?! Also, ET needs to go home.
Building a fully autonomous rover to pick up colored blocks in specified order and drop them at storage location.
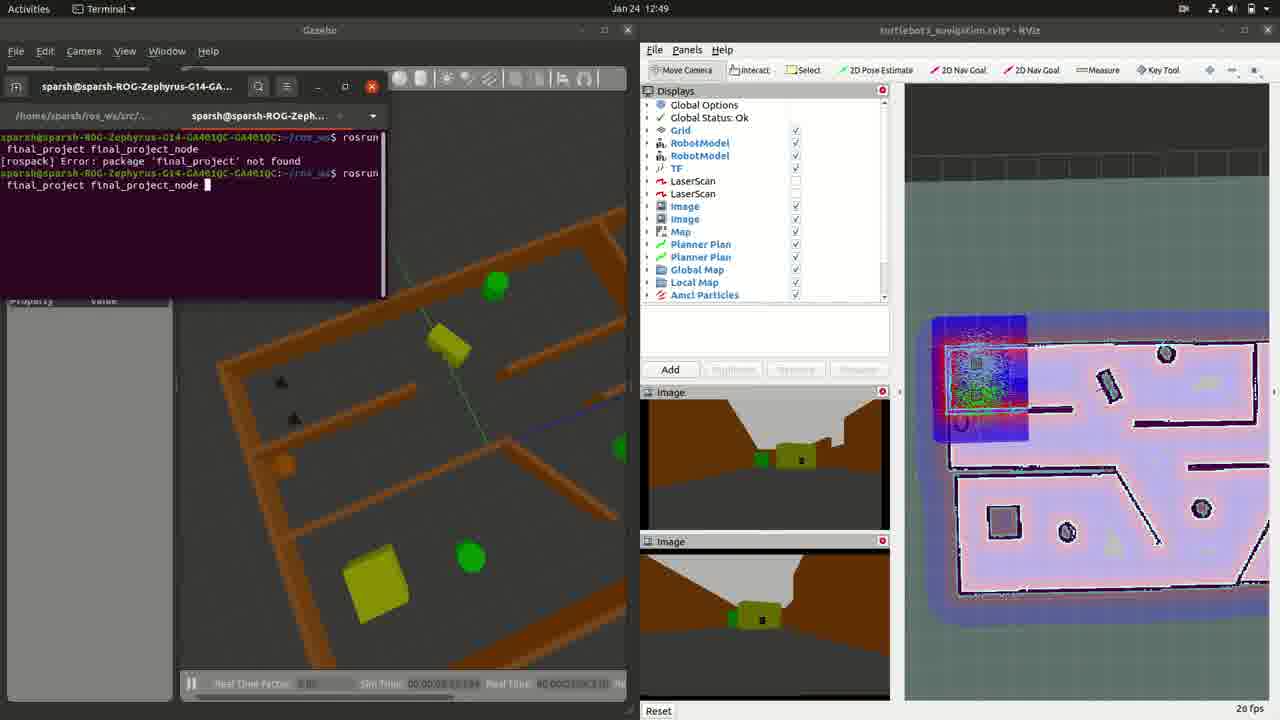
Gazebo and Rviz simulation for the Universal Search & Rescue competition using ROS1 C++.
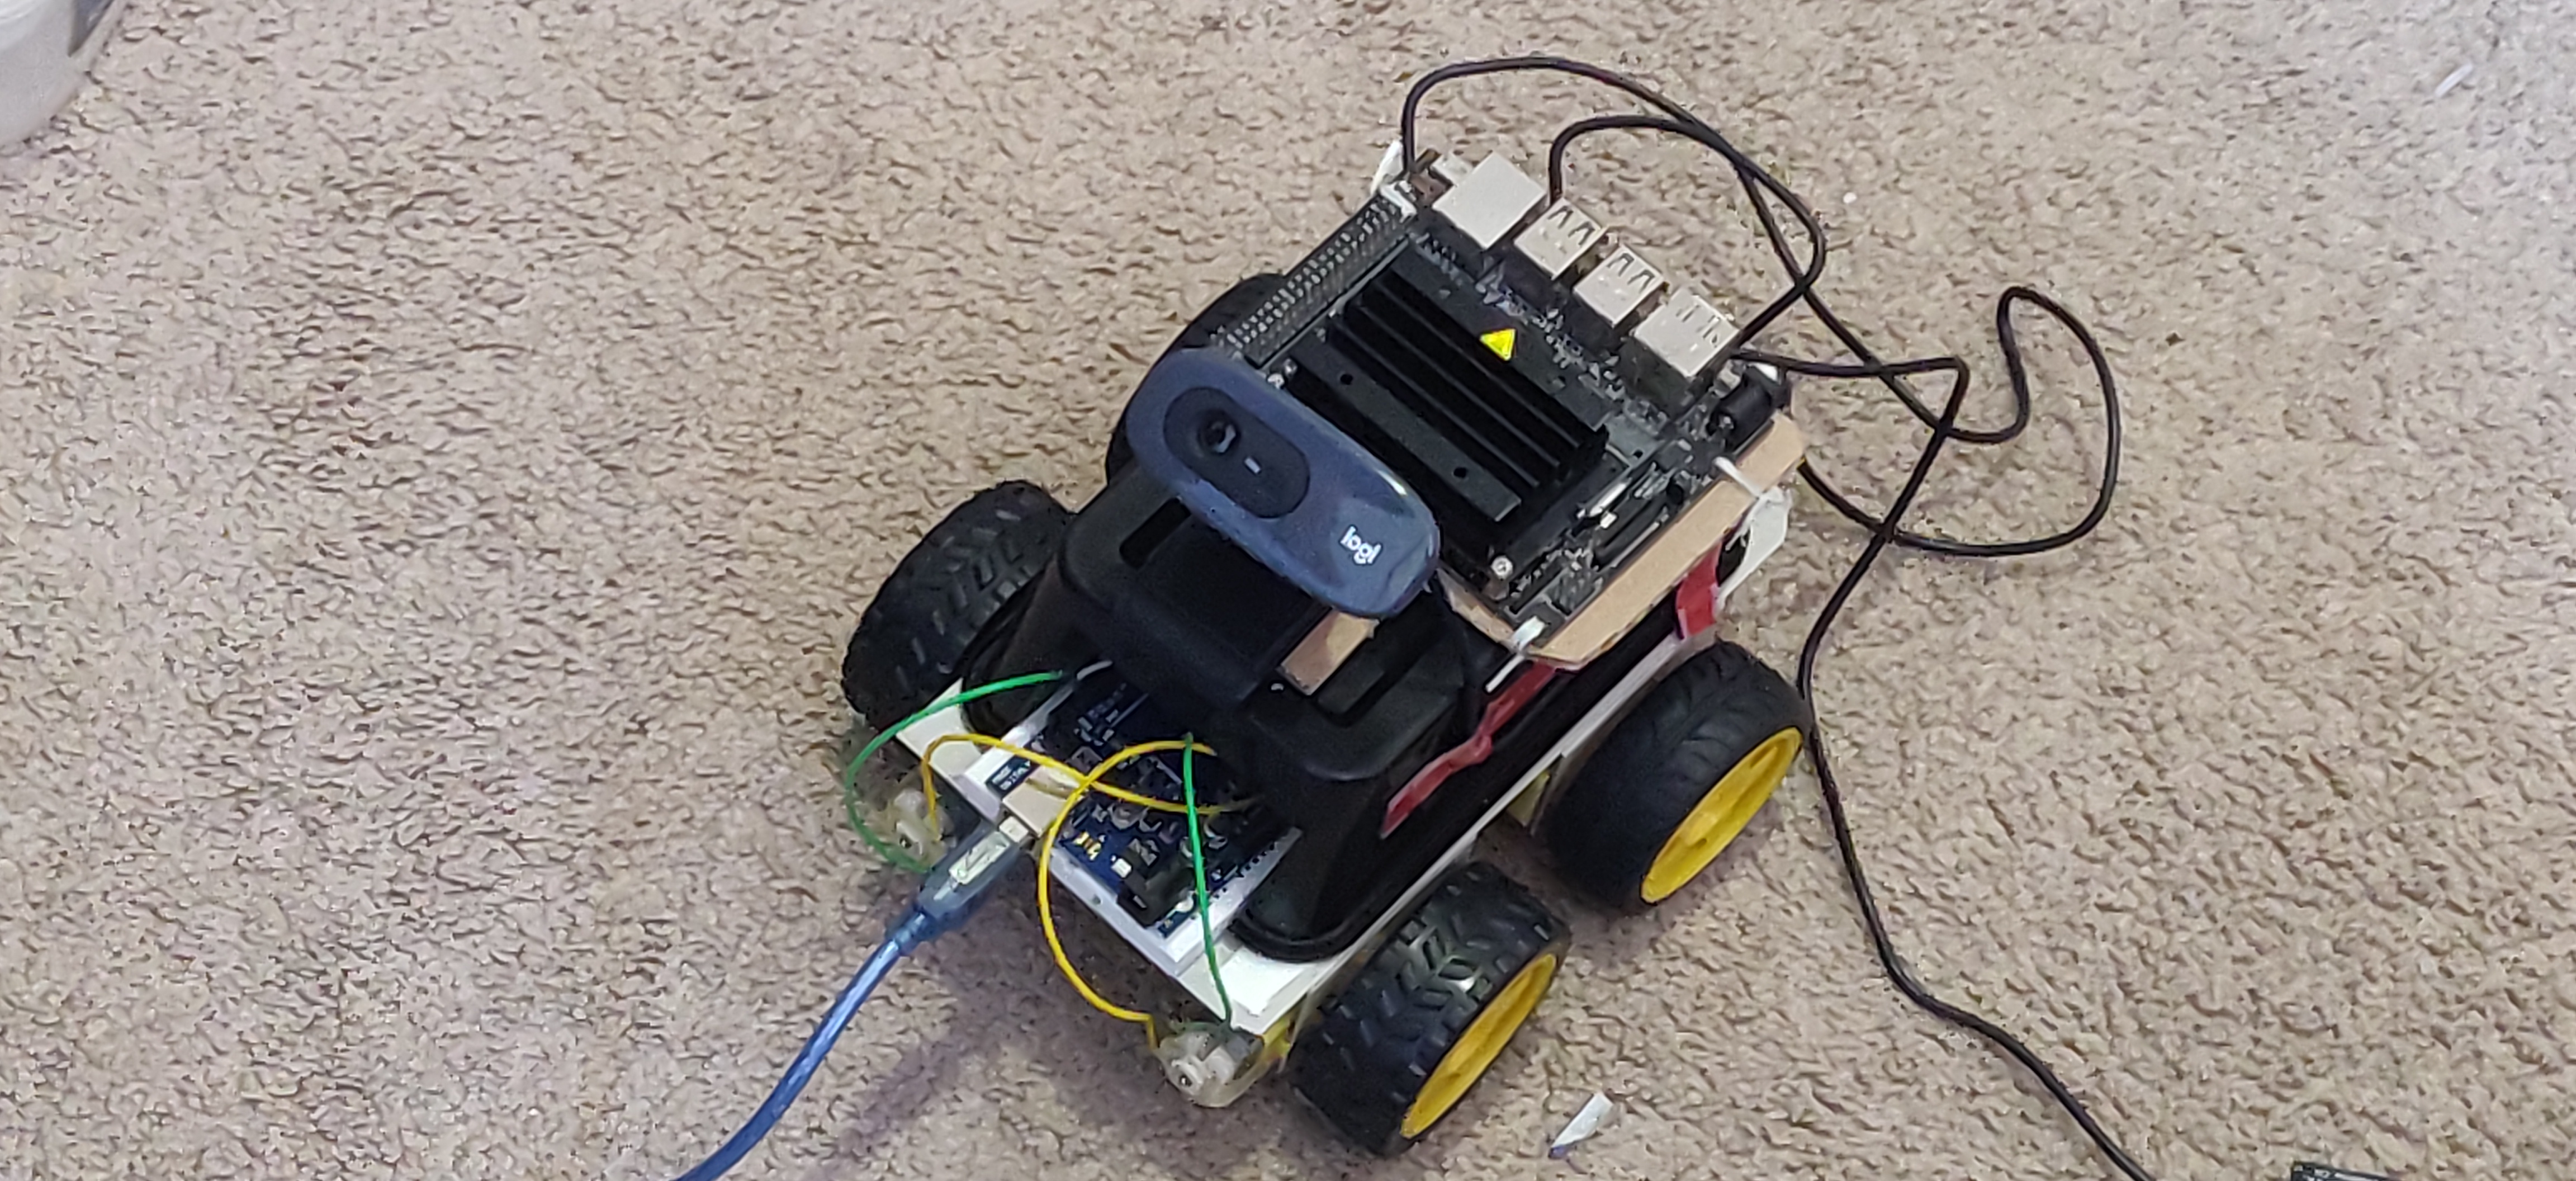
Pose-gesture controlled robot with the Nvidia Jetson Nano to detect poses using the OpenPose model.
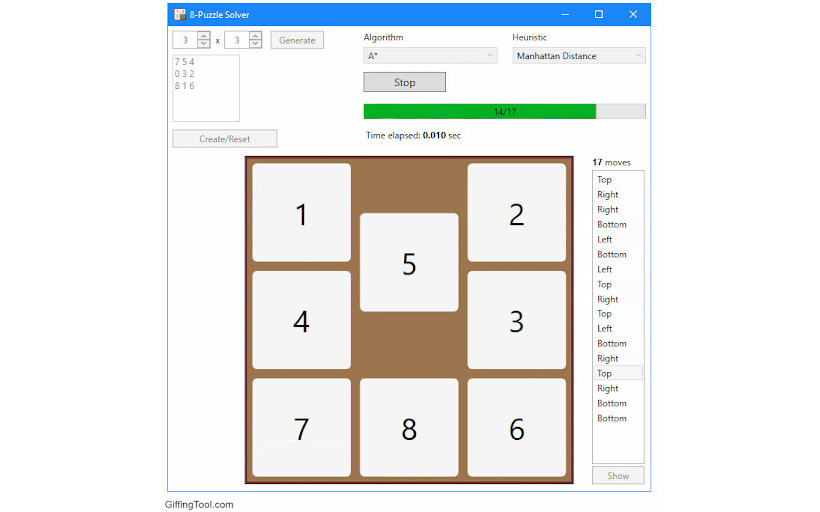
Solving an eight puzzle step by step using the Breadth First Search algorithm.
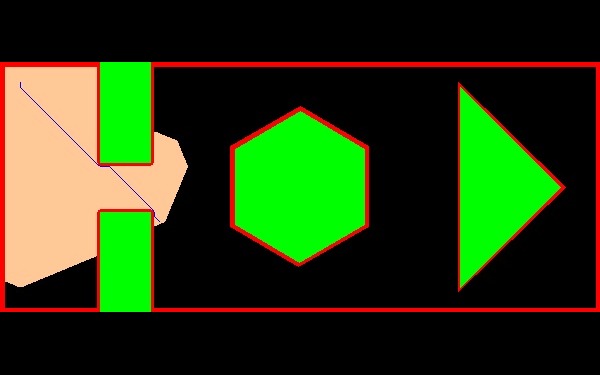
Path Planning for a point robot using the Djikstra's algorithm.
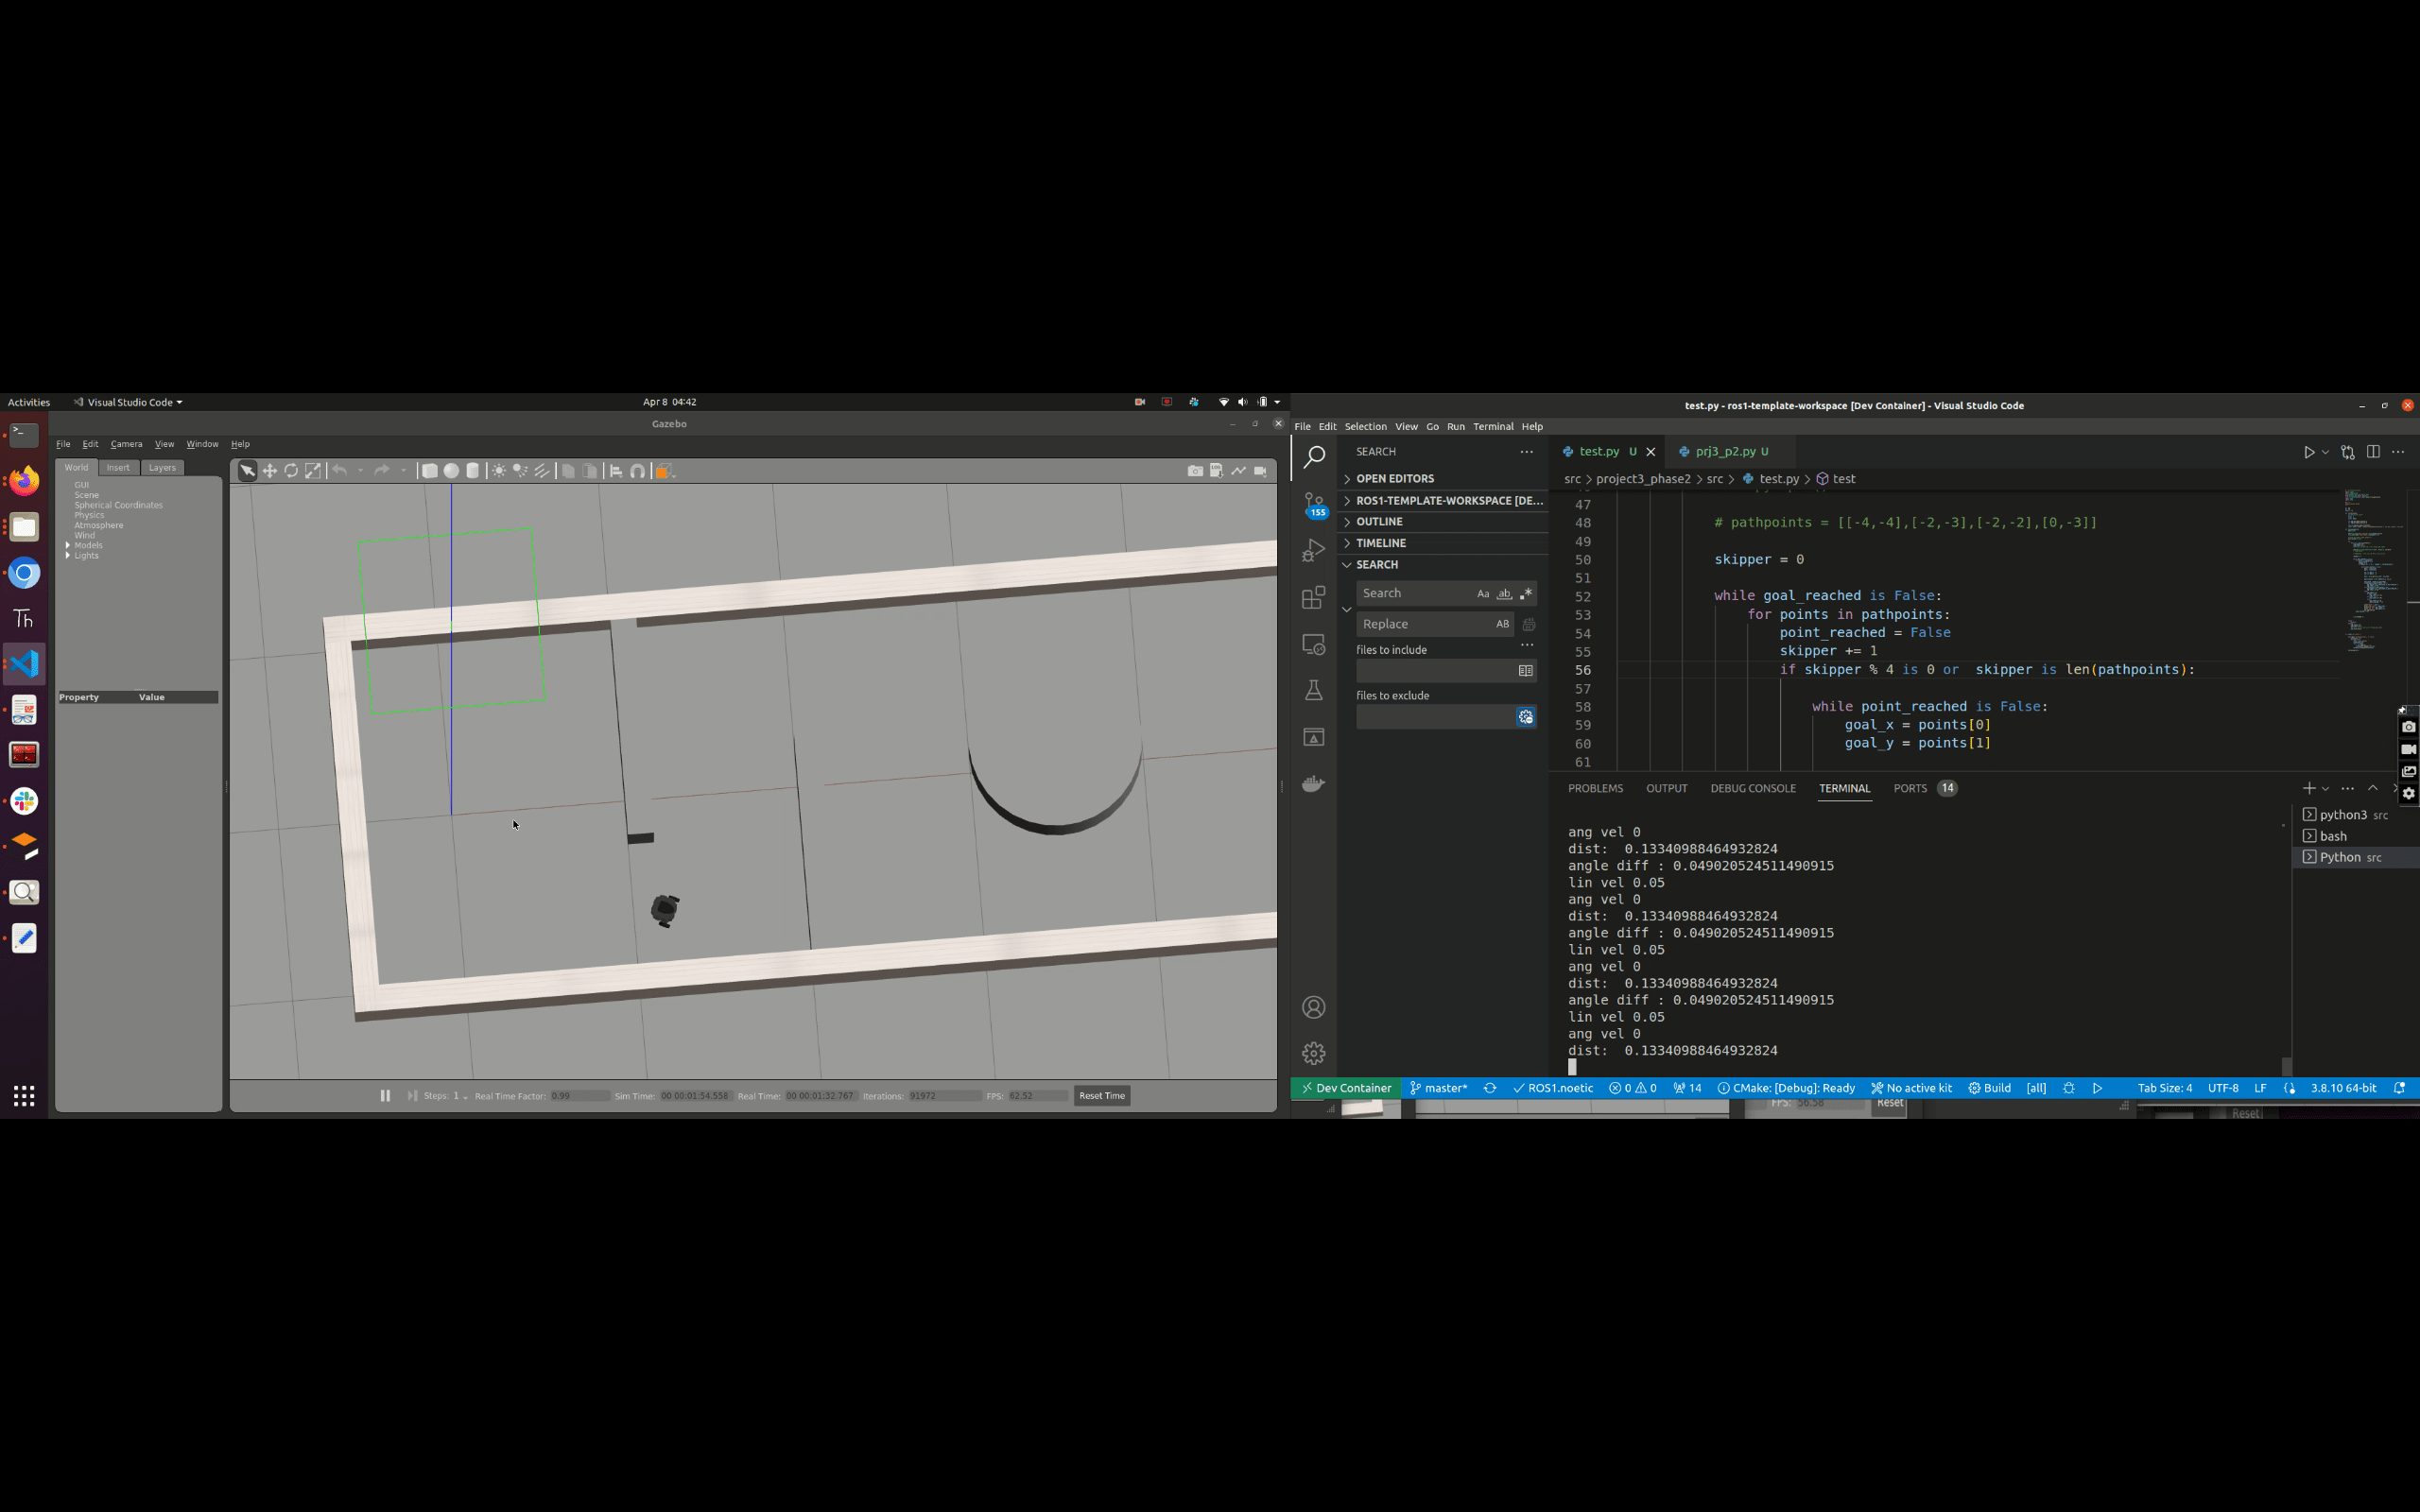
Simulating a turtlebot in Gazebo and planning it's path using the A star algorithm.
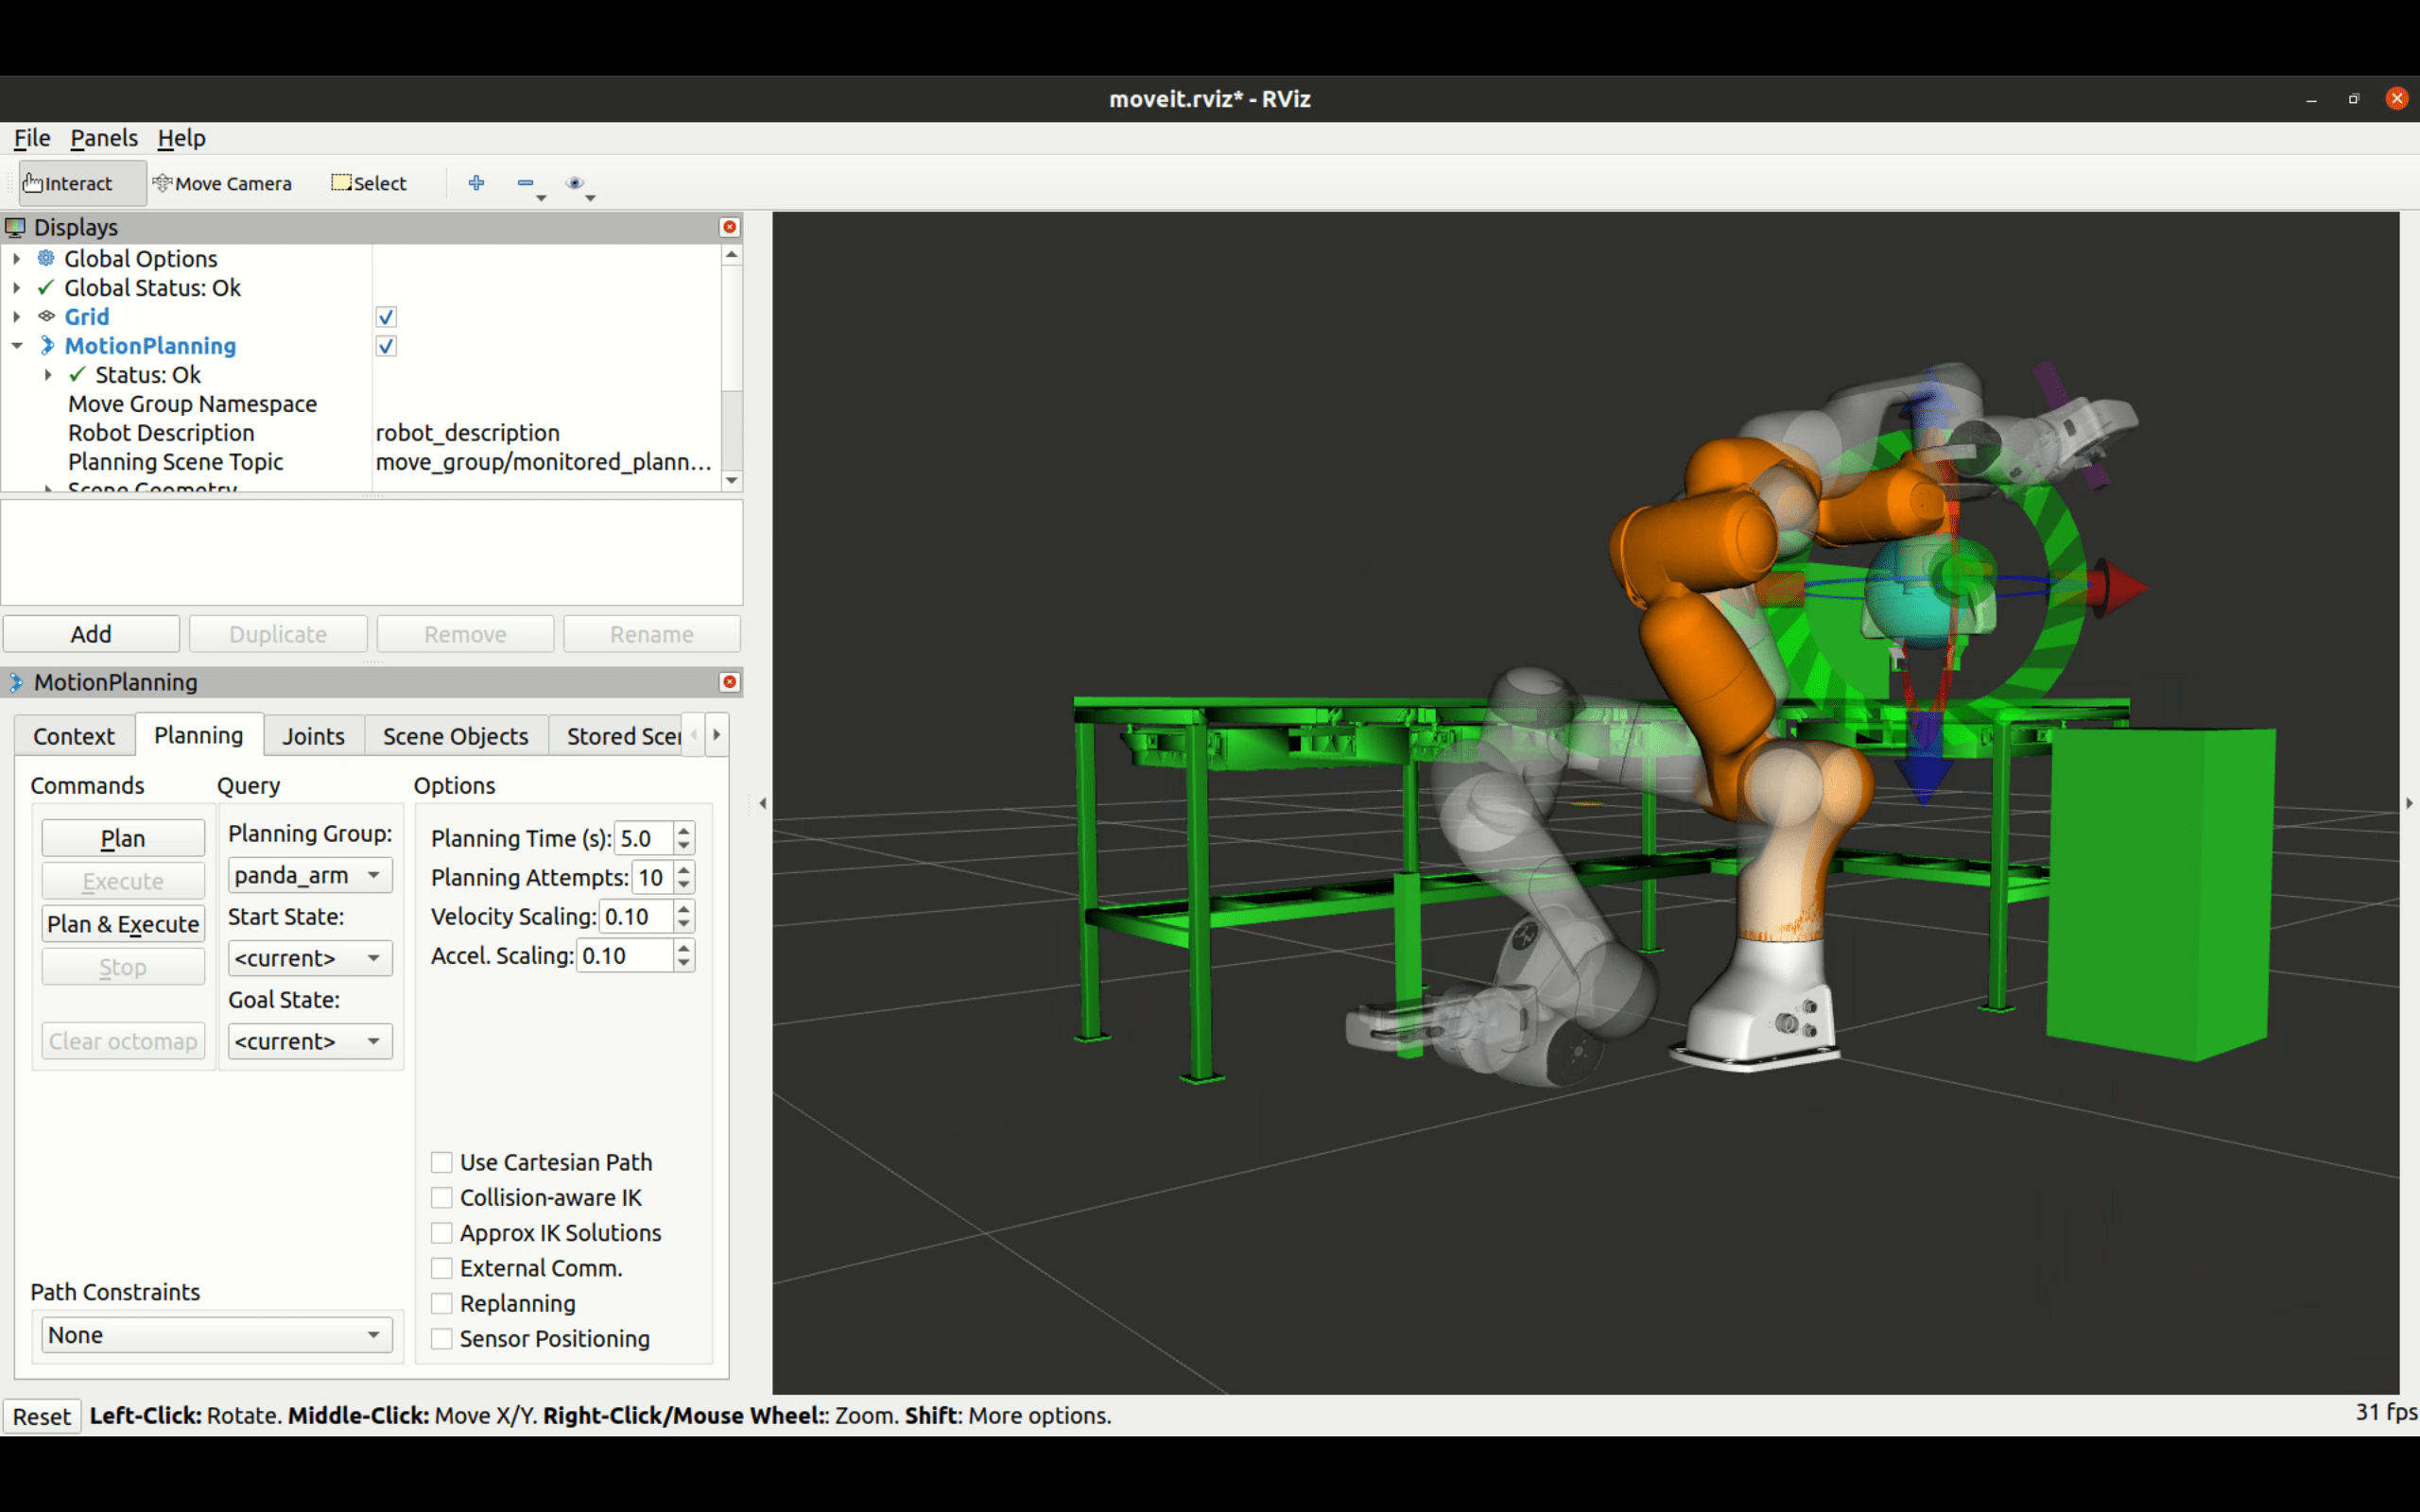
Simulating the Panda robotic arm in Rviz to pick up an object, plan a path around obstacles, and place it on target location.
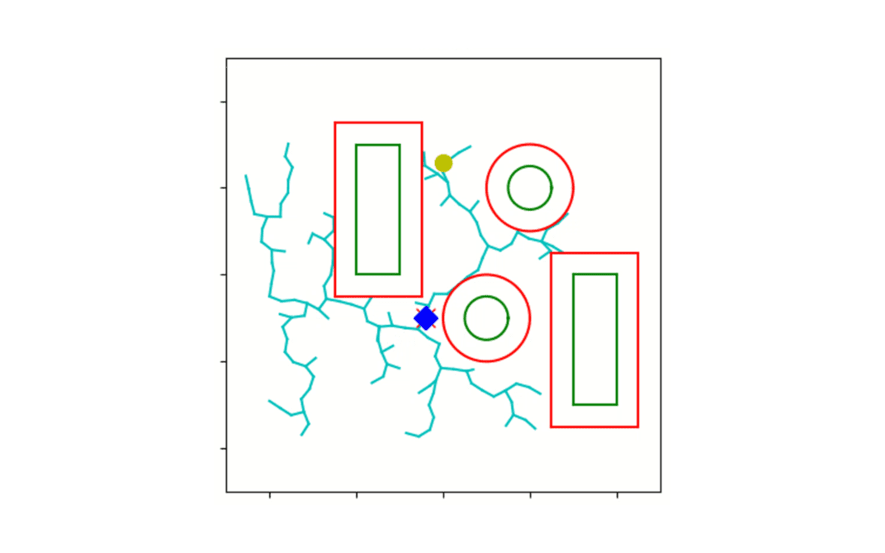
Dynamic planning for a robotic agent in Gazebo (ROS1).
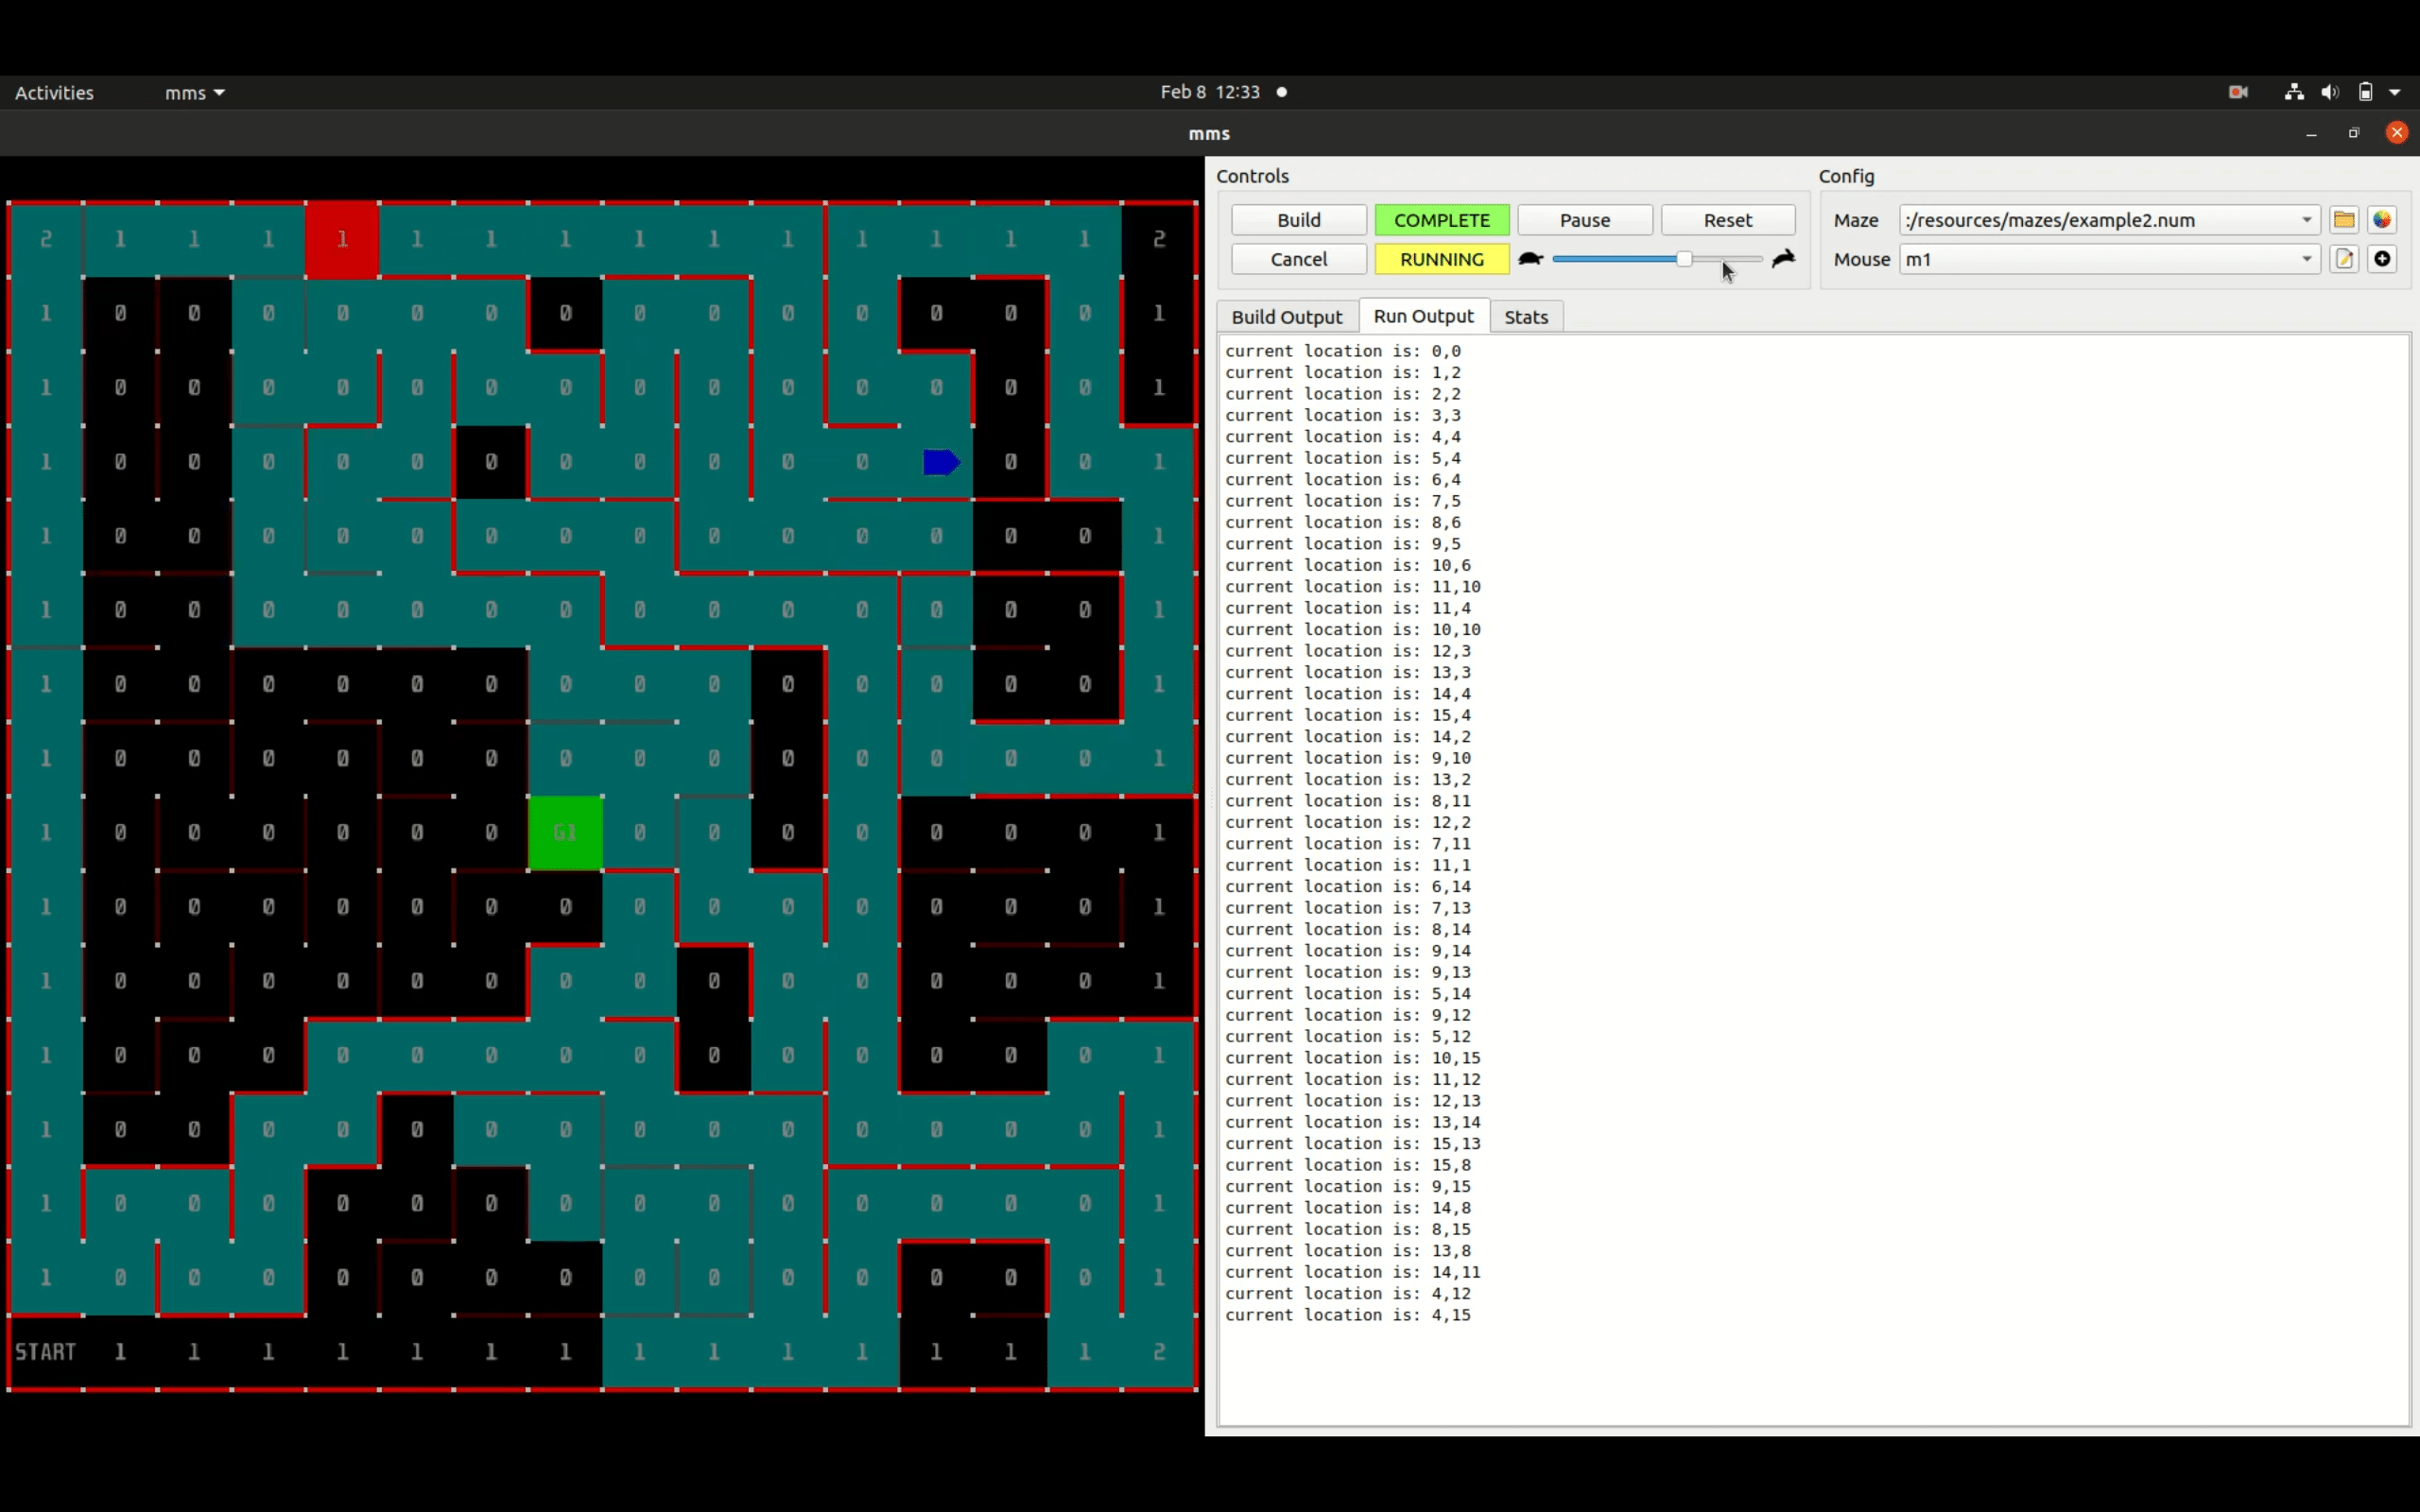
Navigating the micromouse maze simulation using Depth First Search.